- Joints
- 15 degrees of freedom
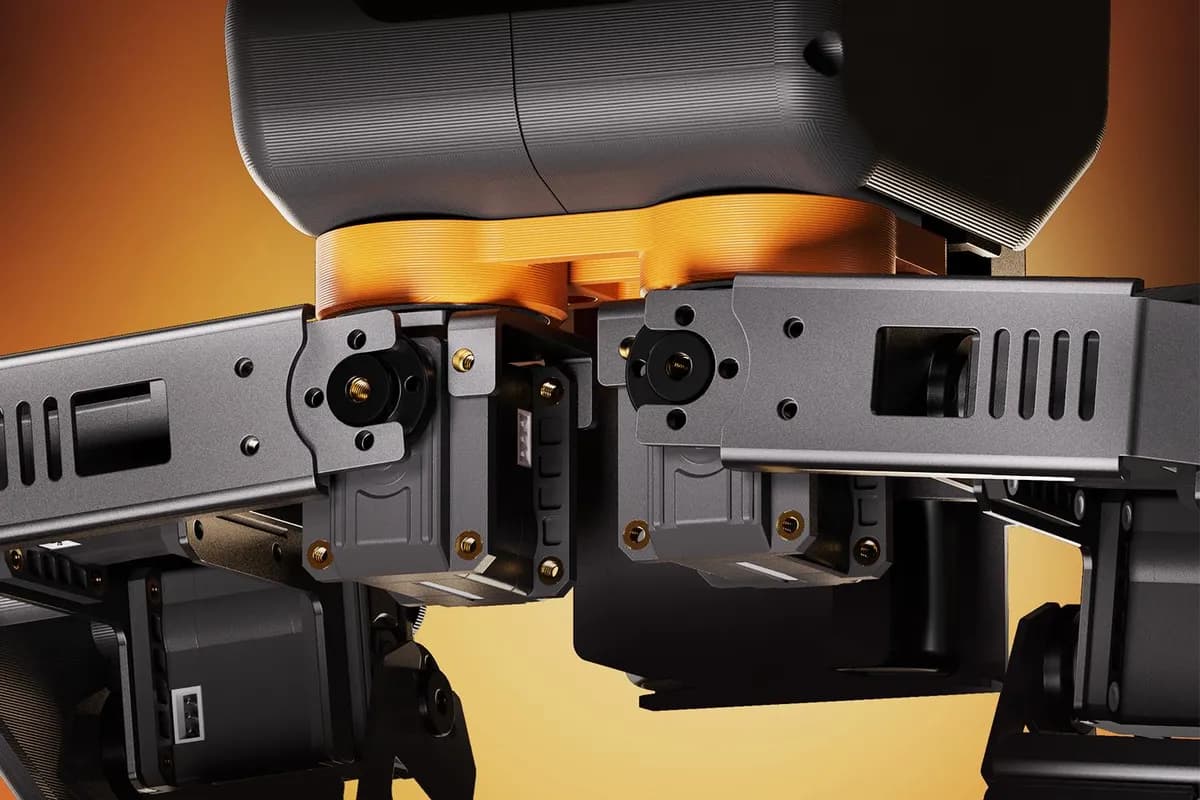
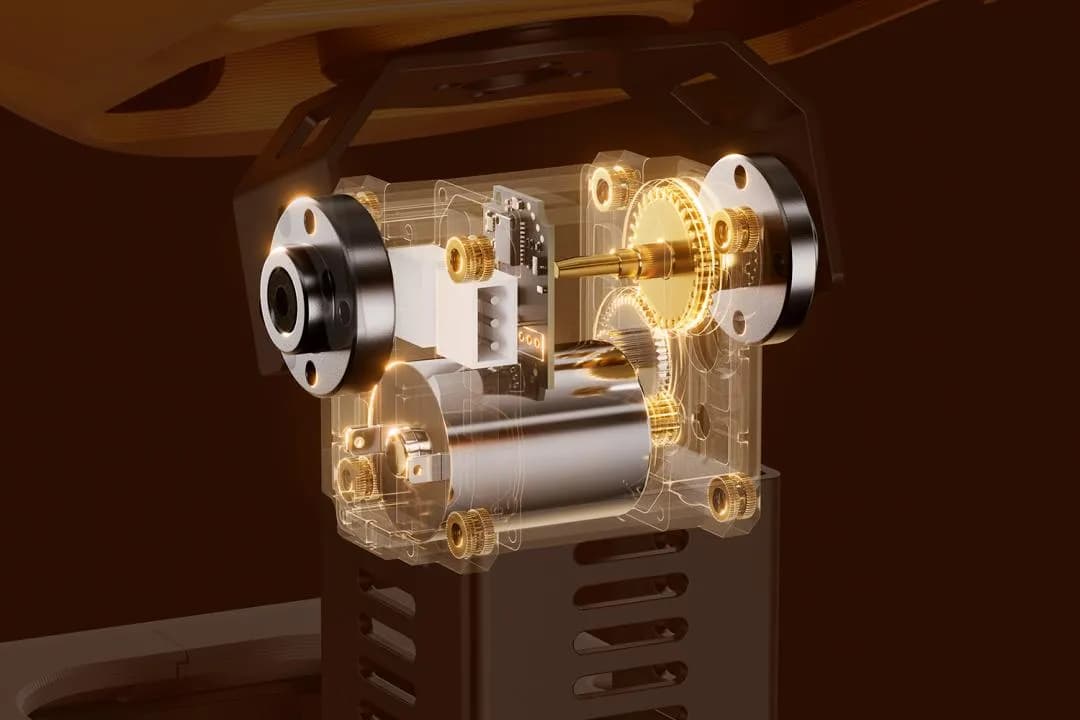
- Joint servos
- HX-08LCM coreless bus servos
- Stall torque
- 8 kg·cm
- Servo speed
- 0.06 s/60°
- Servo feedback
- 12-bit non-contact magnetic encoder
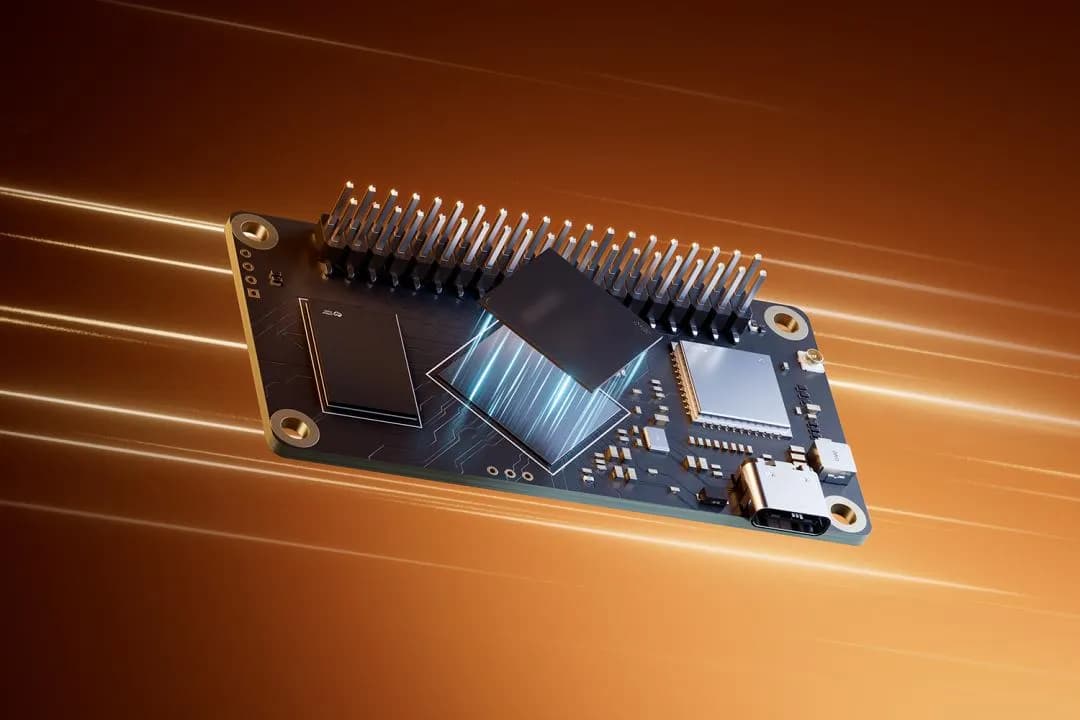
- Main controller
- RK3566, quad-core Cortex-A55
- AI accelerator
- 1 TOPS NPU
- Memory and storage
- 1 GB RAM, 32 GB TF card
- Operating system
- Linux
- Real-time co-processor
- AT32, runs the 50 Hz control loop
- Motion sensors
- Two QMI8658 IMUs, in the head and back
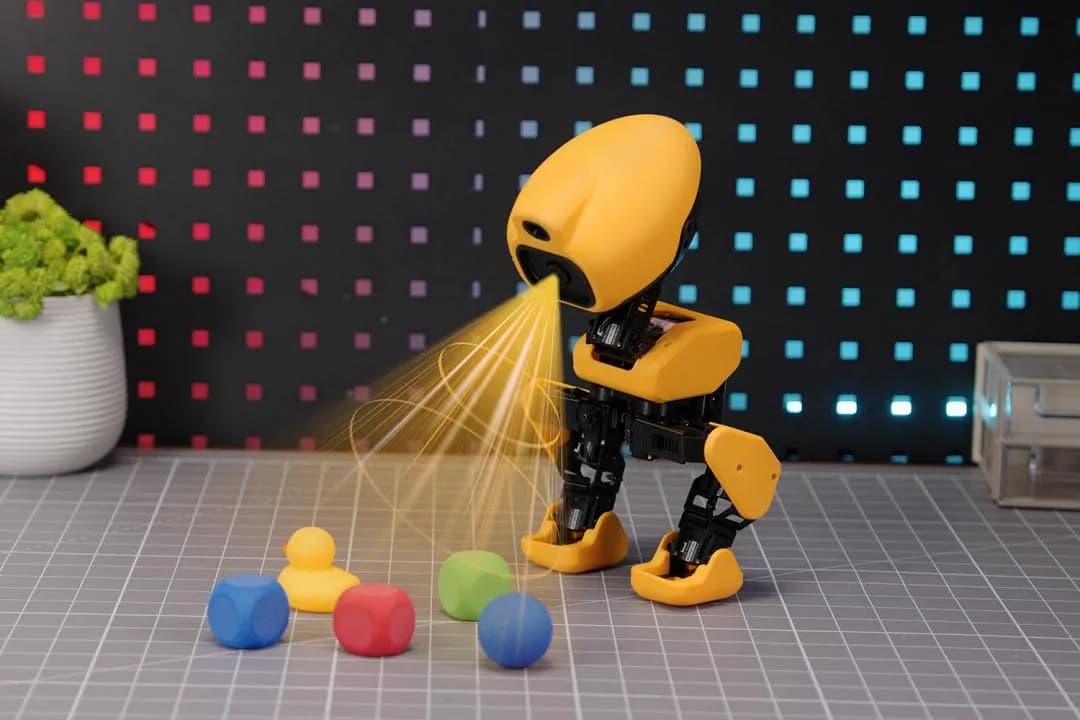
- Camera
- 8-megapixel HD
- Other sensors
- Time-of-flight distance sensor, microphone, speaker
- Battery
- 7.4 V high-rate lithium
- Frame
- Duralumin brackets, modular 3D-printed shell
- Training
- WonderRL: MuJoCo, PPO, mjlab, ONNX export
- Control
- Browser control panel, phone app
Specifications as published by Hiwonder. Size, weight and battery life to follow.