Atom Max Version Flagship 41-DoF humanoid robot, supplied in the UAE.
Flagship
Supplied, integrated and supported by Zeta42 across the UAE and the GCC, with the engineering to put it into a line and the training for the people who will run it afterwards.
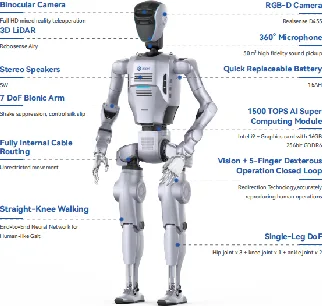
At a glance
- DOF
- 41
- Hands
- 6-DoF x2
- Vision
- 60fps Full HD
- Depth
- RealSense D455
- AI module
- 1500 TOPS
What it does
Built for.
- NDS gives human-like fine motor control for tool use
- AWS gait trained by imitation and reinforcement learning
- Edge computing rated by DOBOT at 7.7x industry-standard computational power
Where it is used
Applications.
- Automotive assembly-line material handling
- Beverage preparation in coffee shops
- Pharmacy night-time dispensing
- Precision assembly and dynamic locomotion research
Specifications
The full sheet.
- Full-body Degree of Freedom 41
- Dexterous hands 6-DoF
- Vision system 60FPS Full HD
- Depth sensing Intel RealSense D455
- AI module 1500 TOPS for real-time edge computing
- VR/MR teleoperation with markerless tracking
- Dual control modes: full-body and segmented
- Optional Embodied AI Set: high-precision URDF models, an open-source training framework and multi-modal data tools
- 360-degree environmental awareness
- 28 upper-body degrees of freedom via the Neuro-Driven Dexterity System (NDS)
- 200Hz high-frequency control with servo-level vibration suppression
- Binocular RGB vision on a Transformer-based architecture
- ROM-1 (Robot Operator Model-1) for task decomposition in unstructured environments
- Anthropomorphic Walking System (AWS): 42% less energy than traditional bent-knee walking
- Adapts to workstation heights of 700 to 1000 mm
Figures published by DOBOT. Performance figures are laboratory results and vary with the application.
Specifications published by DOBOT: DOBOT ATOM on dobot-robots.com.
In the same range
Humanoids.
- LUMO L1 Standard (Education edition)
- LUMO L1 Max (Training edition)
- Atom Data Collection Version
- ATOM-W
Specification sheets answer the second question. The first one is usually whether a robot suits the job at all, and that is answered by watching the task rather than by reading a table, which is what an assessment visit is for.
Pricing is quoted case by case.