DOBOT+ ecosystem
Everything that goes on the end of the arm.
Robot projects rarely fail at the arm. They fail at the edges. The gripper does not talk to the controller, the camera wants a driver nobody has, the force sensor arrives with an SDK of its own. Every one of those is a delay, and none of them is visible when you are comparing arms on payload.
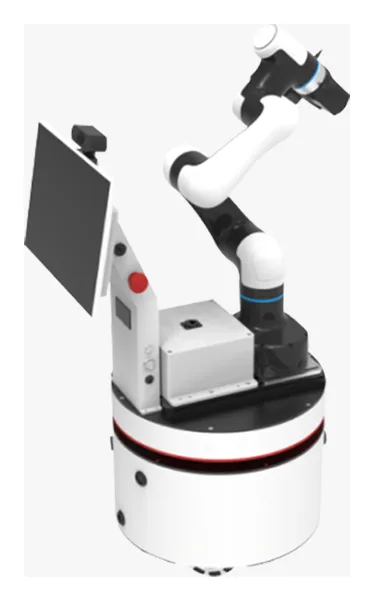
Plus the DOBOT+ ecosystem: grippers, smart cameras and 3D vision, force sensors, sanding heads, Siemens PLC integration and mobile bases.
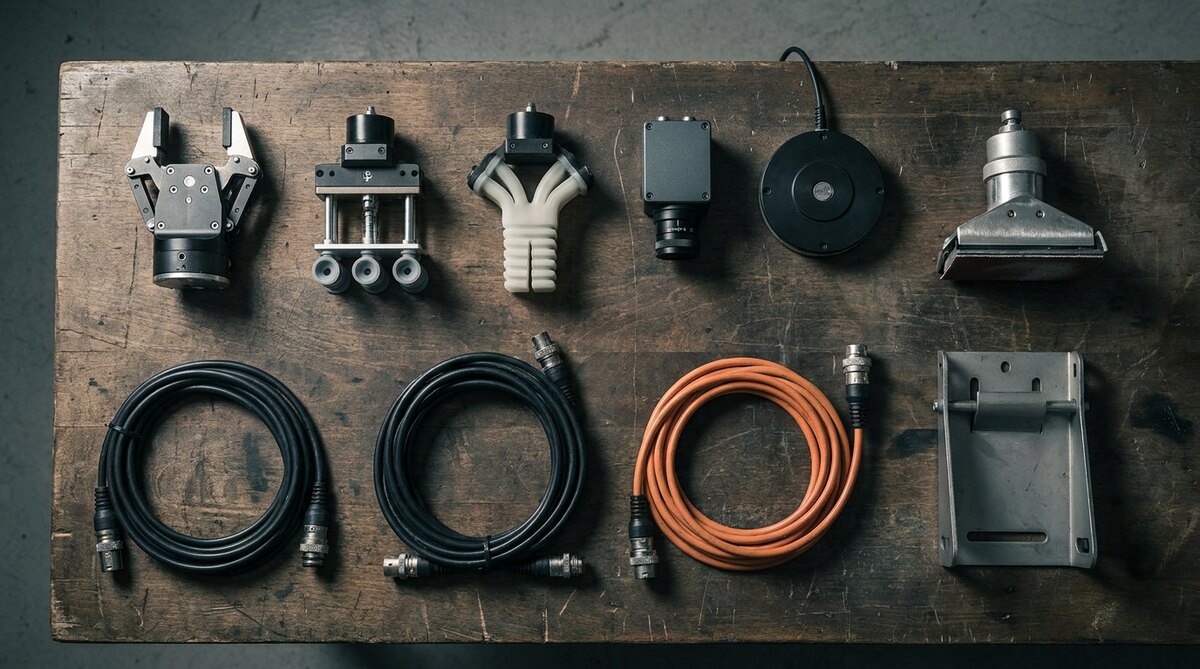
What an arm needs
The end of the arm does the work.
An arm on its own is a general-purpose thing. What makes it useful is what you bolt to the end of it and what it can see. The gripper decides which parts it can hold, the camera decides whether it can find them, and the force sensor decides how gently it can put them down.
Choosing those is where a project either moves or stalls, and it is usually done last, by whoever is left. We specify them alongside the arm instead, so what you are quoted is one working cell rather than a robot and a list of things to sort out later.
Certified
Tested against the arm first.
A certified ecosystem is the answer to that. Accessories in the programme are certified against the arms, so they connect out of the box and are supported as one system rather than as a shelf of parts that ought to work together.
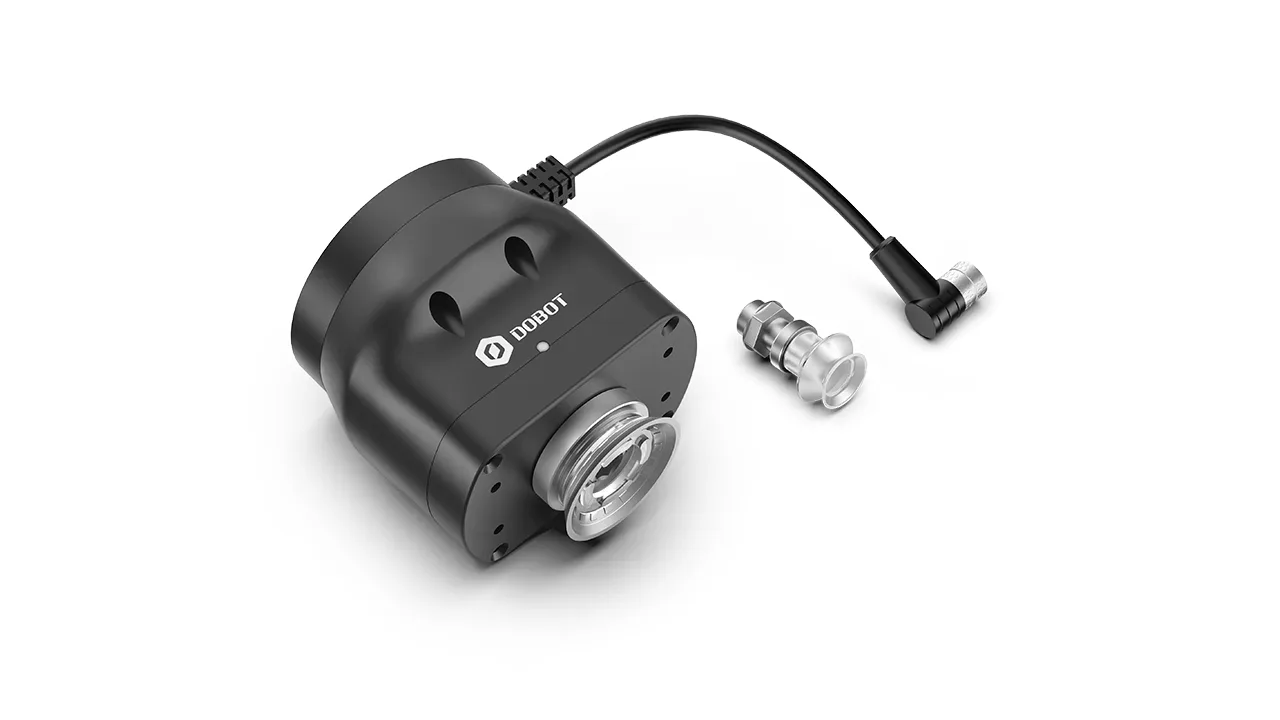
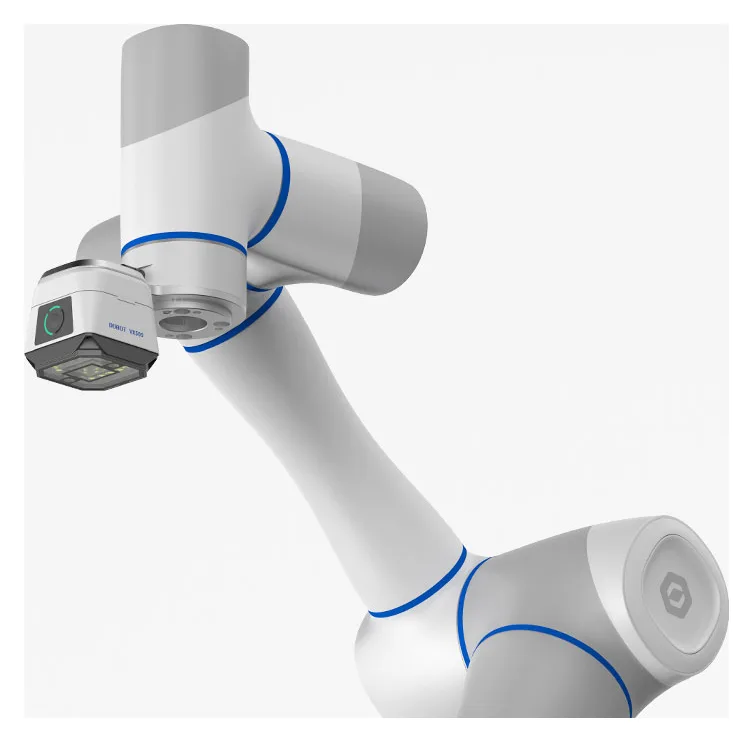
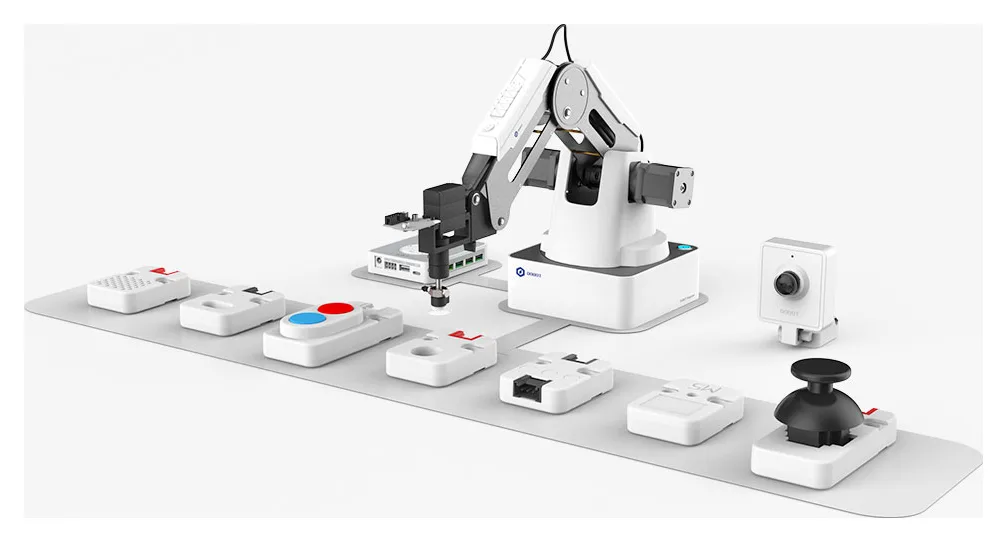
- Grippers
- Smart cameras and 3D vision
- Force sensors
- Sanding heads
- Siemens PLC integration
- Mobile bases
Plug and play
Certified grippers, cameras, force sensors and mobile bases connect out of the box.
Who integrates it
Our problem, not yours.
We hold the integration on our side. If a gripper and a controller disagree, that is our problem to solve, not a ticket you file and wait on.
Book a DOBOT demo at the Zeta42 campus, or request an on-site application assessment.