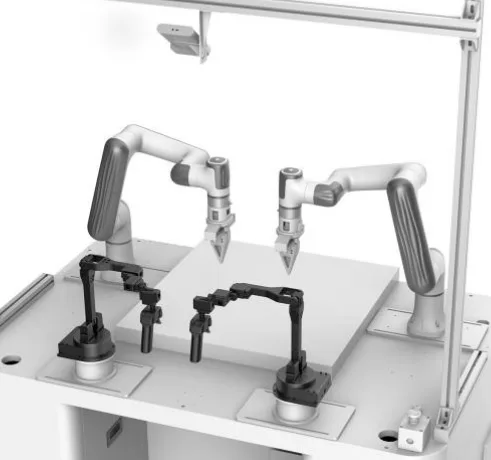
X-Trainer: Dual-Arm Teleoperation Data Collection Station
Imitation Learning
Supplied, integrated and supported by Zeta42 across the UAE and the GCC, with the engineering to put it into a line and the training for the people who will run it afterwards.
What it does
Built for.
- Training time cut 70%: routine scenarios trainable in around 2 hours
- Real-time disturbance correction during autonomous tasks
- Master hand unlock and record buttons; spring-assisted low-fatigue chassis
- Auto de-sync of master/slave arms on power loss or alarm; drop detection
- Full SDK covering data collection, model training and autonomous inference
- Open APIs for joint angles, gripper control and camera RGB/depth
Where it is used
Applications.
- AGI scene simulation and research
- Practical AI projects and competitions
- Imitation-learning task training (dish-washing, clothes folding cited)
- Bimanual teleoperation and robot data collection
Specifications
The full sheet.
- Master Robot × 2: 6-axis high-precision teleoperation hand with grippers, including unlocking and recording functions (Standard)
- Slave Robots Nova-2 × 2: high-precision collaborative arms, accuracy ±0.05 mm, payload 2 kg, arm span 625 mm (Standard)
- Slave Robot Gripper × 2: max opening/closing distance 95 mm; shipped with master robot (Standard)
- Camera × 3: depth camera; shipped with master robot (Standard)
- Robot Fixing × 1: robot fixing base with global camera bracket (Standard)
- Training PC × 1: recommended: RTX 4090 24 GB + Intel i9-14900KF, 32 GB, 2 TB (NOT included)
- Reach 625 mm per arm, expandable to 1200 mm in dual-arm mode
- Payload 2 kg single-arm, 3 kg dual-arm
- Repeat positioning accuracy ±0.05 mm · top speed 1.6 m/s
- 25 Hz end-to-end motion interface: response 150% faster than comparable products
- Master hand under 400 g, 3D-printed monolithic joints
- Built on the Nova 2 cobot: 5-level collision detection, ISO 15066 certified
Figures published by DOBOT. Performance figures are laboratory results and vary with the application.
Specifications published by DOBOT: DOBOT X-Trainer on dobot-robots.com.
Specification sheets answer the second question. The first one is usually whether a robot suits the job at all, and that is answered by watching the task rather than by reading a table, which is what an assessment visit is for.
Pricing is quoted case by case.