M1 Pro SCARA Robot
SCARA
Supplied, integrated and supported by Zeta42 across the UAE and the GCC, with the engineering to put it into a line and the training for the people who will run it afterwards.
What it does
Built for.
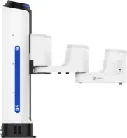
- All-in-one design with integrated control box: plug-and-play and portable
- Forearm 40% narrower than a traditional industrial arm to reduce accidental bumping
- Collision detection for human-machine collaboration
- Encoder interface supporting dynamic grabbing and conveyor tracking
- Multithreading and on-the-fly IO control to cut cycle time
Where it is used
Applications.
- Loading and unloading, assembly, gluing, quality inspection, transporting
- Automotive, food & beverage, consumer electronics, healthcare
Specifications
The full sheet.
- SCARA configuration · payload 1.5 kg · working radius 400 mm
- Repeatability ±0.02 mm · weight 15.7 kg · IP20
- J1 ±85°, J2 ±130°, J3 5 to 245 mm, J4 ±360°
- Max joint speed J1/J2 180°/s, J3 1000 mm/s, J4 1000°/s
- TCP/IP, Modbus TCP and Modbus RTU · 100 to 240 V AC
Figures published by DOBOT. Performance figures are laboratory results and vary with the application.
Specifications published by DOBOT: M1 Pro on dobot-robots.com.
In the same range
Compact and desktop industrial arms.
- Nova 2
- Nova 5
- MG400 Robot
- Vision System
Specification sheets answer the second question. The first one is usually whether a robot suits the job at all, and that is answered by watching the task rather than by reading a table, which is what an assessment visit is for.
Pricing is quoted case by case.