E6 AMMR: Autonomous Mobile Manipulation Robot
ROS / SLAM
Supplied, integrated and supported by Zeta42 across the UAE and the GCC, with the engineering to put it into a line and the training for the people who will run it afterwards.
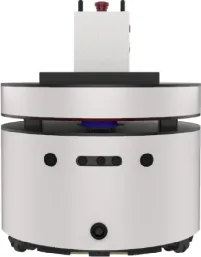
At a glance
- Payload
- ≤50kg
- Weight
- ≤25kg
What it does
Built for.
- Related technologies named by DOBOT: SLAM mapping, intelligent obstacle avoidance, autonomous navigation, path planning, deep-vision AI recognition, and vision-based mobile grasping
- Independently suspended wheels able to rotate on the spot
- Dual LiDAR minimum with configurable 2D/3D cameras
Where it is used
Applications.
- Object recognition, localisation, grasping and transportation
- Vision-based mobile grasping experiments for indoor robots
Specifications
The full sheet.
- Dimension ≤520*520*350mm
- Weight ≤25kg
- Maximum Payload ≤50kg
- Rated Voltage 24V
- Battery Life ≥6h (no load); >2h (with load)
- Navigation Accuracy ±5cm
- Critical Stop Precision 5mm
- LiDAR Accuracy ±3cm
- Range Measurement ≥20m
- Motion Performance Max speed: ≥0.5m/s
- Drive System Independently suspended wheels with spot rotation capability
- Main Controller Industrial PC with ROS communication for custom development
- Processor Specifications RAM: ≥4GB
- Storage: ≥64GB
- Development Support ROS-based custom development supported
- Supported Camera Types Configurable 2D/3D cameras
- Sensor Parameters Dual LiDAR (minimum)
- Other sensors unrestricted
- Compatible robot type is listed as the Magician E6
- Industrial PC main controller with ROS communication for custom development
Figures published by DOBOT. Performance figures are laboratory results and vary with the application.
Specifications published by DOBOT: DOBOT E6 ROS Mobile Platform on dobot-robots.com.
In the same range
Work cells and training platforms.
- Training Platform (excluding PLC)
Specification sheets answer the second question. The first one is usually whether a robot suits the job at all, and that is answered by watching the task rather than by reading a table, which is what an assessment visit is for.
Pricing is quoted case by case.