ATOM-W
Wheeled
Supplied, integrated and supported by Zeta42 across the UAE and the GCC, with the engineering to put it into a line and the training for the people who will run it afterwards.
At a glance
- Payload
- 3.5 kg per arm
- Reach
- 600 mm
- Repeatability
- ±0.05 mm
- Speed
- 1.5 m/s
What it does
Built for.
- NDS gives human-like fine motor control for tool use and multi-spec handling
- AWS gait trained by imitation plus reinforcement learning
- ROM-1 decomposes complex tasks autonomously in unstructured environments
- Multi-robot collaboration with integrated human-robot safety technology
- Edge computing rated at 7.7× industry-standard computational power
Where it is used
Applications.
- Automotive assembly-line material handling
- Beverage preparation in coffee shops
- Pharmacy night-time dispensing
- Multi-device service scenarios and production lines
- Precision assembly and dynamic locomotion research
Specifications
The full sheet.
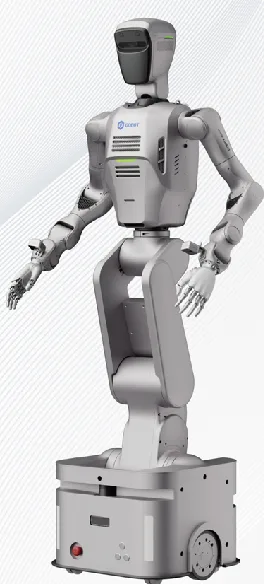
- ATOM-W is an industrial-grade wheeled humanoid robot integrating high-precision dual-arm manipulation, autonomous mobile navigation, and end-to-end AI intelligence.
- Standard Configuration:
- Dimensions: ~1785 × 500 × 500 mm (H×W×D)
- DOF (excluding dexterous hands): 20 (Head: 2 + Arms: 7×2 + Waist: 4)
- Arm Payload: 3.5 kg per arm
- Arm Reach: 600 mm
- Repeatability: ±0.05 mm
- Max Speed: 1.5 m/s
- Navigation: LiDAR-based
- Vertical Positioning Accuracy: ±10 mm
- Perception: 1 × Depth Camera + 1 × Stereo HD Camera (head-mounted)
- Audio: 1 × 360° Microphone + 2 × Calibrated Speakers
- Battery: 45 Ah
- Onboard Compute: Intel Core i9 (24C/32T) + High-performance GPU (41.15 TFLOPS FP32)
- SDK Support for Custom Development
- Optional Upgrades:
- 6-DOF Dexterous Hands
- 2 × Hand-mounted Depth Cameras
- 2 × Waist-mounted Depth Cameras
- 6-Axis Force/Torque Sensors at End Effectors
- 28 upper-body degrees of freedom via the Neuro-Driven Dexterity System (NDS)
- 200 Hz high-frequency control with servo-level vibration suppression
- Binocular RGB vision on a Transformer-based architecture
- ROM-1 model: 100M parameters, 24 Hz end-to-end control
- Anthropomorphic Walking System (AWS): straight-knee gait, 42% less energy than bent-knee
- Adapts to workstation heights of 700 to 1000 mm
- ATOM Max variant: 41 DoF, 6-DoF dexterous hands, Intel RealSense D455, 1500 TOPS, VR/MR teleoperation with markerless tracking
Figures published by DOBOT. Performance figures are laboratory results and vary with the application.
Specifications published by DOBOT: DOBOT ATOM on dobot-robots.com.
In the same range
Humanoids.
- LUMO L1 Standard (Education edition)
- LUMO L1 Max (Training edition)
- Atom Data Collection Version
- Atom Trainer Version
- Atom Max Version
Specification sheets answer the second question. The first one is usually whether a robot suits the job at all, and that is answered by watching the task rather than by reading a table, which is what an assessment visit is for.
Pricing is quoted case by case.