Atom Trainer Version
Trainer
Supplied, integrated and supported by Zeta42 across the UAE and the GCC, with the engineering to put it into a line and the training for the people who will run it afterwards.
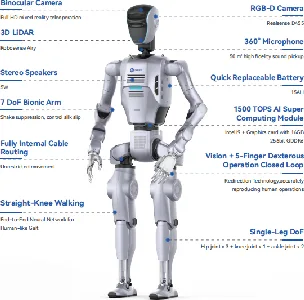
At a glance
- Payload
- 3.5kg
- Reach
- 600mm
- Repeatability
- ±0.05mm
- DOF
- 29
- Speed
- 1.5m/s
- Weight
- 62kg
What it does
Built for.
- NDS gives human-like fine motor control for tool use and multi-spec handling
- AWS gait trained by imitation plus reinforcement learning
- ROM-1 decomposes complex tasks autonomously in unstructured environments
- Multi-robot collaboration with integrated human-robot safety technology
- Edge computing rated at 7.7× industry-standard computational power
Where it is used
Applications.
- Automotive assembly-line material handling
- Beverage preparation in coffee shops
- Pharmacy night-time dispensing
- Multi-device service scenarios and production lines
- Precision assembly and dynamic locomotion research
Specifications
The full sheet.
- Height 1650mm
- Weight (without dexterous hands) 62kg
- Full-body Degree of Freedom 29
- Head Degree of Freedom 2
- Single Arm Degrees of Freedom 7
- Waist Degree of Freedom 1
- Single Leg Degree of Freedom 6
- Single Arm Span (without dexterous hands) 600mm
- Single Arm Load 3.5kg
- Single Arm Repetitive Positioning Accuracy ±0.05mm
- Maximum End-Speed of Arm 1.5m/s
- Basic Computing Module Intel i5
- 1500 TOPS AI Computing Module Intel i9 (24 cores 32 threads)+ Graphics card with 16GB256bit GDDR6 (FP32 GPU computing power: 41.15 TFLOPS)
- Head Sensor RGB-D Camera*1+Full HD Binocular Camera *1
- Battery Charge 1hour
- Head LiDAR 3D LiDAR *1
- 28 upper-body degrees of freedom via the Neuro-Driven Dexterity System (NDS)
- 200 Hz high-frequency control with servo-level vibration suppression
- Binocular RGB vision on a Transformer-based architecture
- ROM-1 model: 100M parameters, 24 Hz end-to-end control
- Anthropomorphic Walking System (AWS): straight-knee gait, 42% less energy than bent-knee
- Adapts to workstation heights of 700 to 1000 mm
- ATOM Max variant: 41 DoF, 6-DoF dexterous hands, Intel RealSense D455, 1500 TOPS, VR/MR teleoperation with markerless tracking
Figures published by DOBOT. Performance figures are laboratory results and vary with the application.
Specifications published by DOBOT: DOBOT ATOM on dobot-robots.com.
In the same range
Humanoids.
- LUMO L1 Standard (Education edition)
- LUMO L1 Max (Training edition)
- Atom Data Collection Version
- Atom Max Version
- ATOM-W
Specification sheets answer the second question. The first one is usually whether a robot suits the job at all, and that is answered by watching the task rather than by reading a table, which is what an assessment visit is for.
Pricing is quoted case by case.